Whole-Body
Control
Hierarchical objectives and constraints across coupled mobile and humanoid systems.
- HQP / QP
- Redundancy resolution
- Joint & workspace limits
Robotics control engineer · Shenzhen
I'm Jarvis Men (门嘉伟). I build reliable control systems for humanoid robots—connecting task-level intent to smooth, constraint-aware motion on real hardware.
Expertise
I work across algorithms, runtime architecture and hardware integration—the layers that determine whether a robot motion is merely possible or genuinely reliable.
Hierarchical objectives and constraints across coupled mobile and humanoid systems.
Continuous trajectory generation from sparse goals and streamed commands.
Deterministic command flow, observation and recovery around real robot motion.
Bridging learned policies with classical constraints and hardware-aware execution.
Selected projects
Representative systems spanning whole-body control, learned-policy execution and production-oriented manipulation.
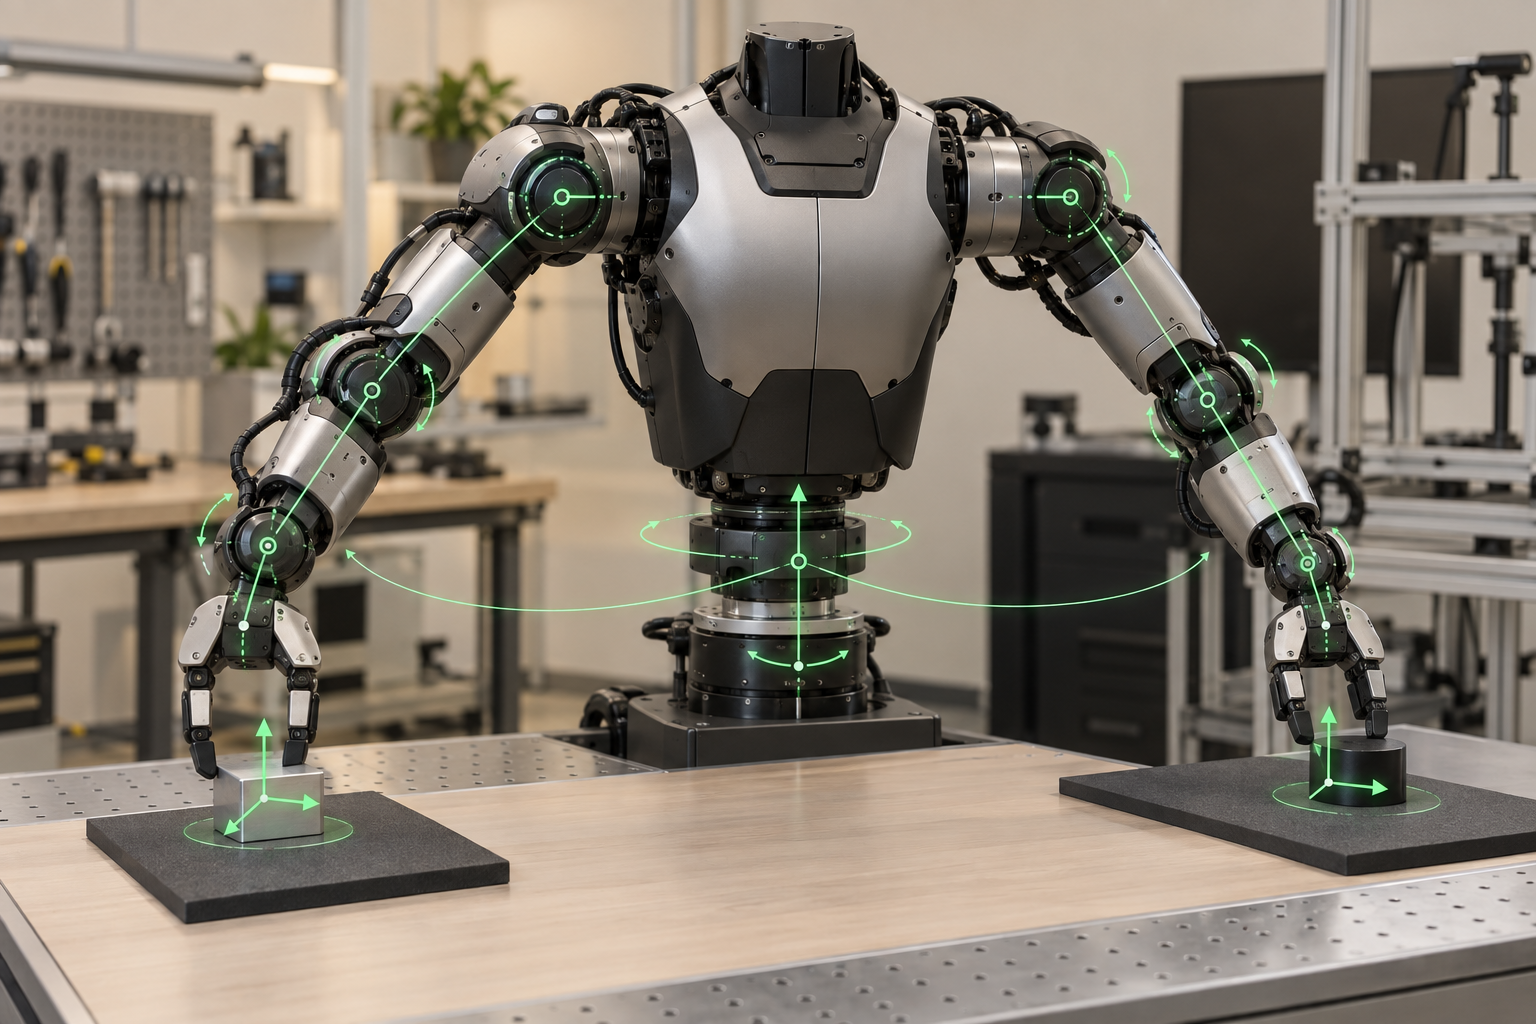
A real-time whole-body motion stack coordinating two 7-DoF arms and a 3-DoF torso from end-effector goals to stable joint commands.
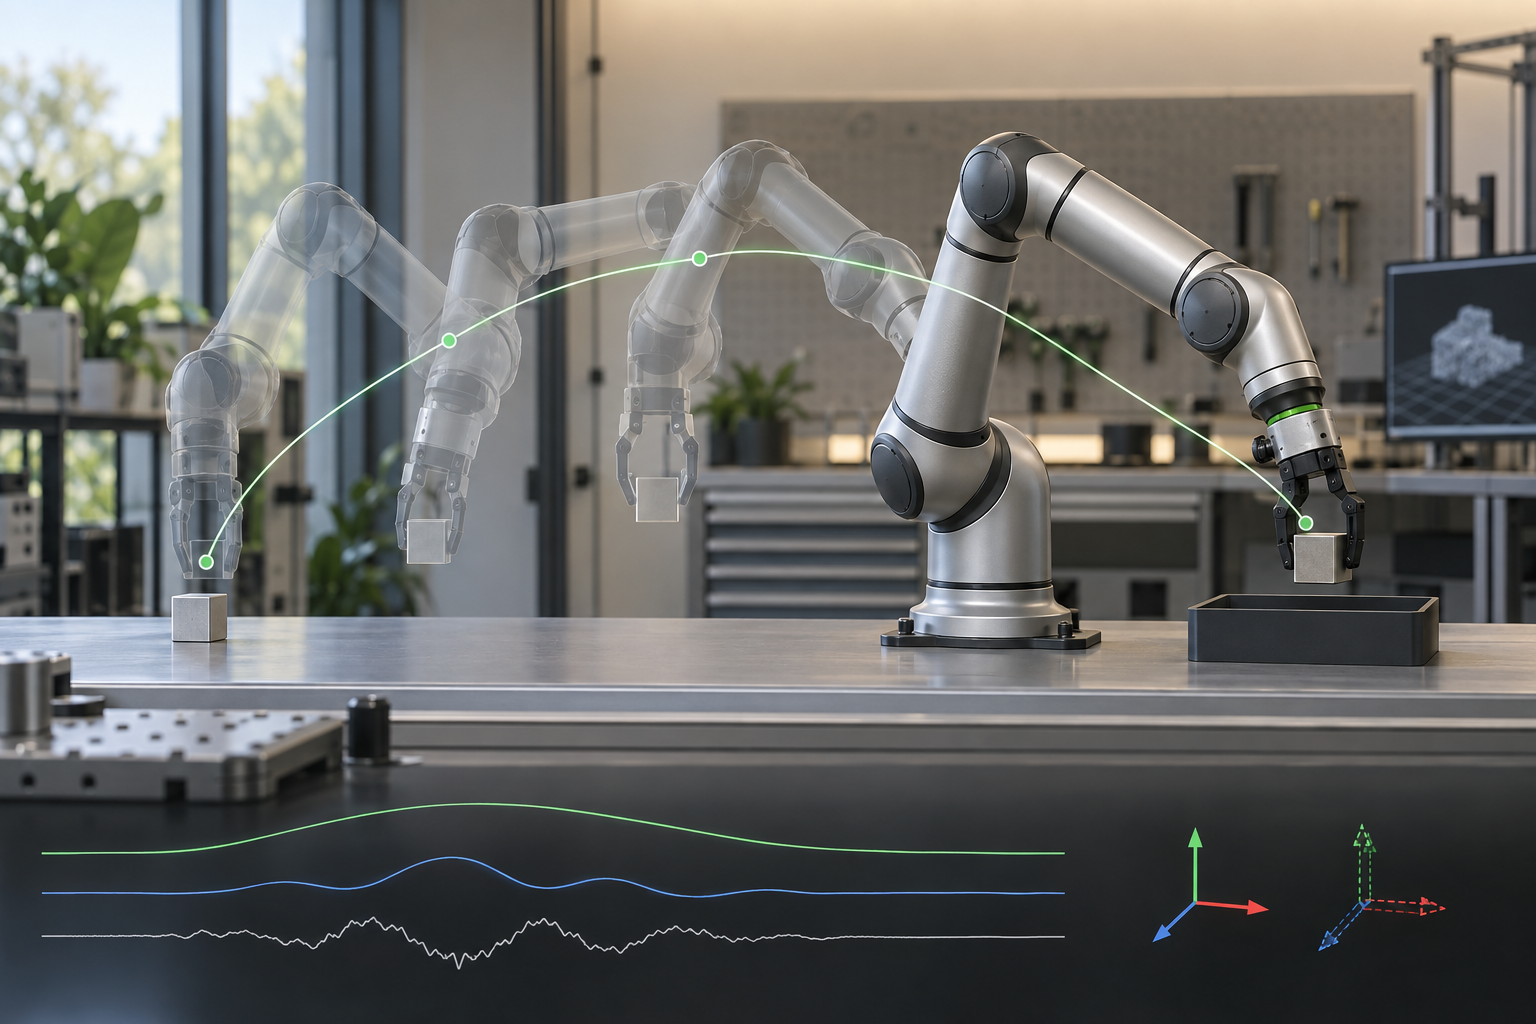
A constraint-aware execution layer that turns model-generated action chunks into continuous, observable and hardware-safe motion.
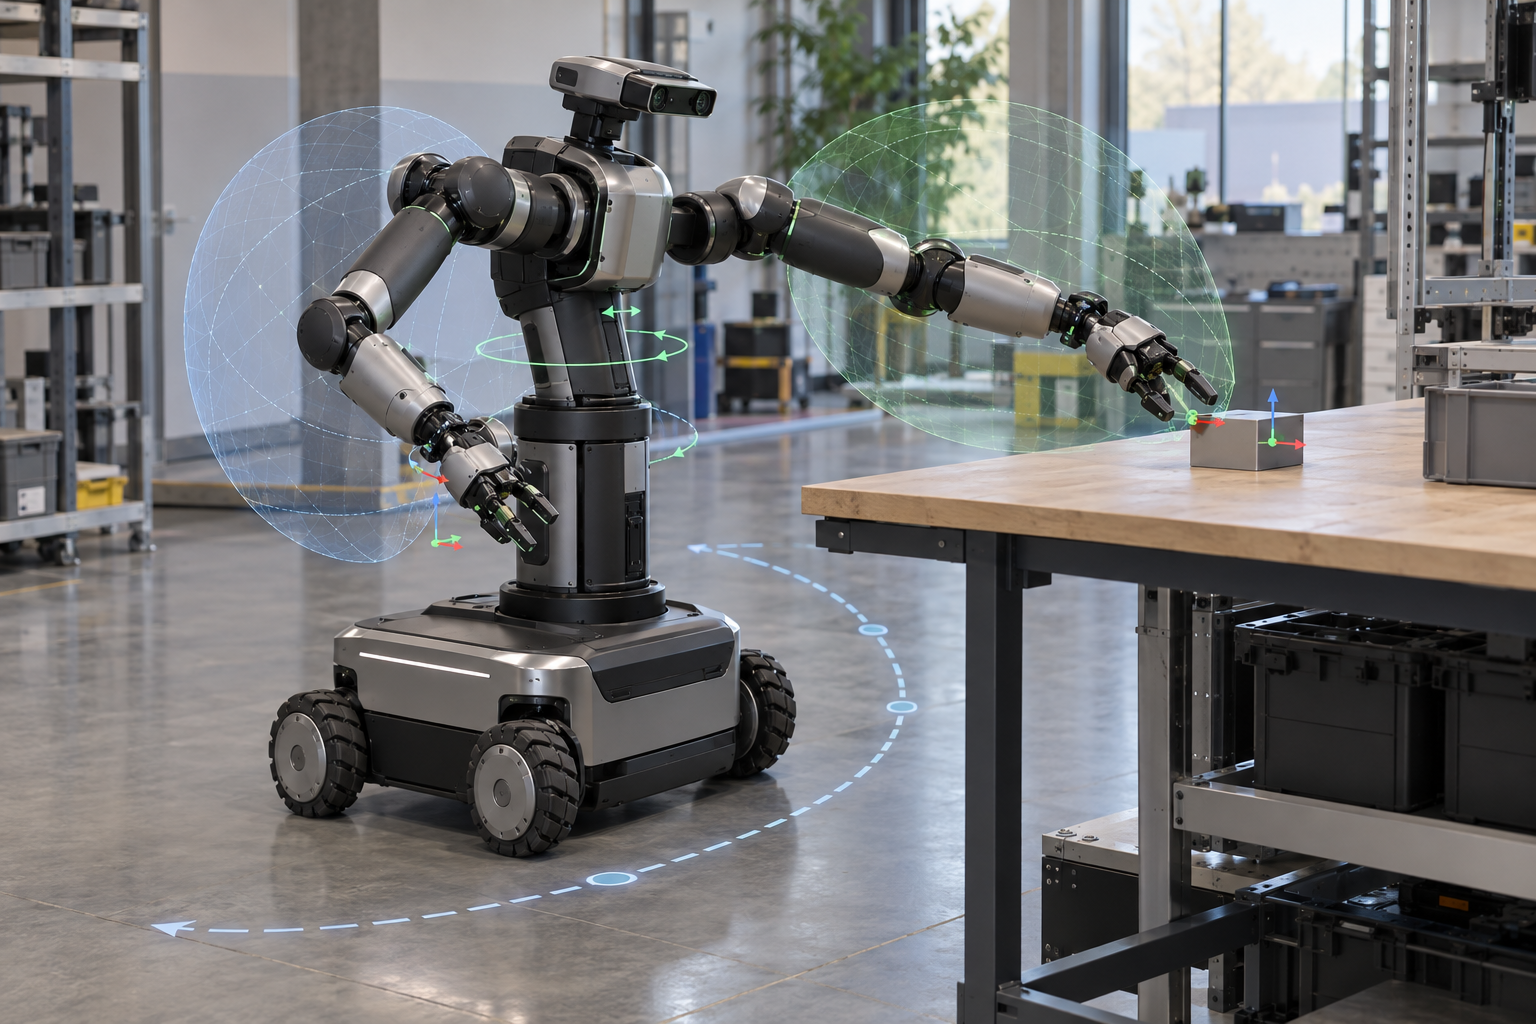
Unified coordination for a mobile base, torso and dual arms—balancing reachability, posture and task tracking across the full kinematic chain.
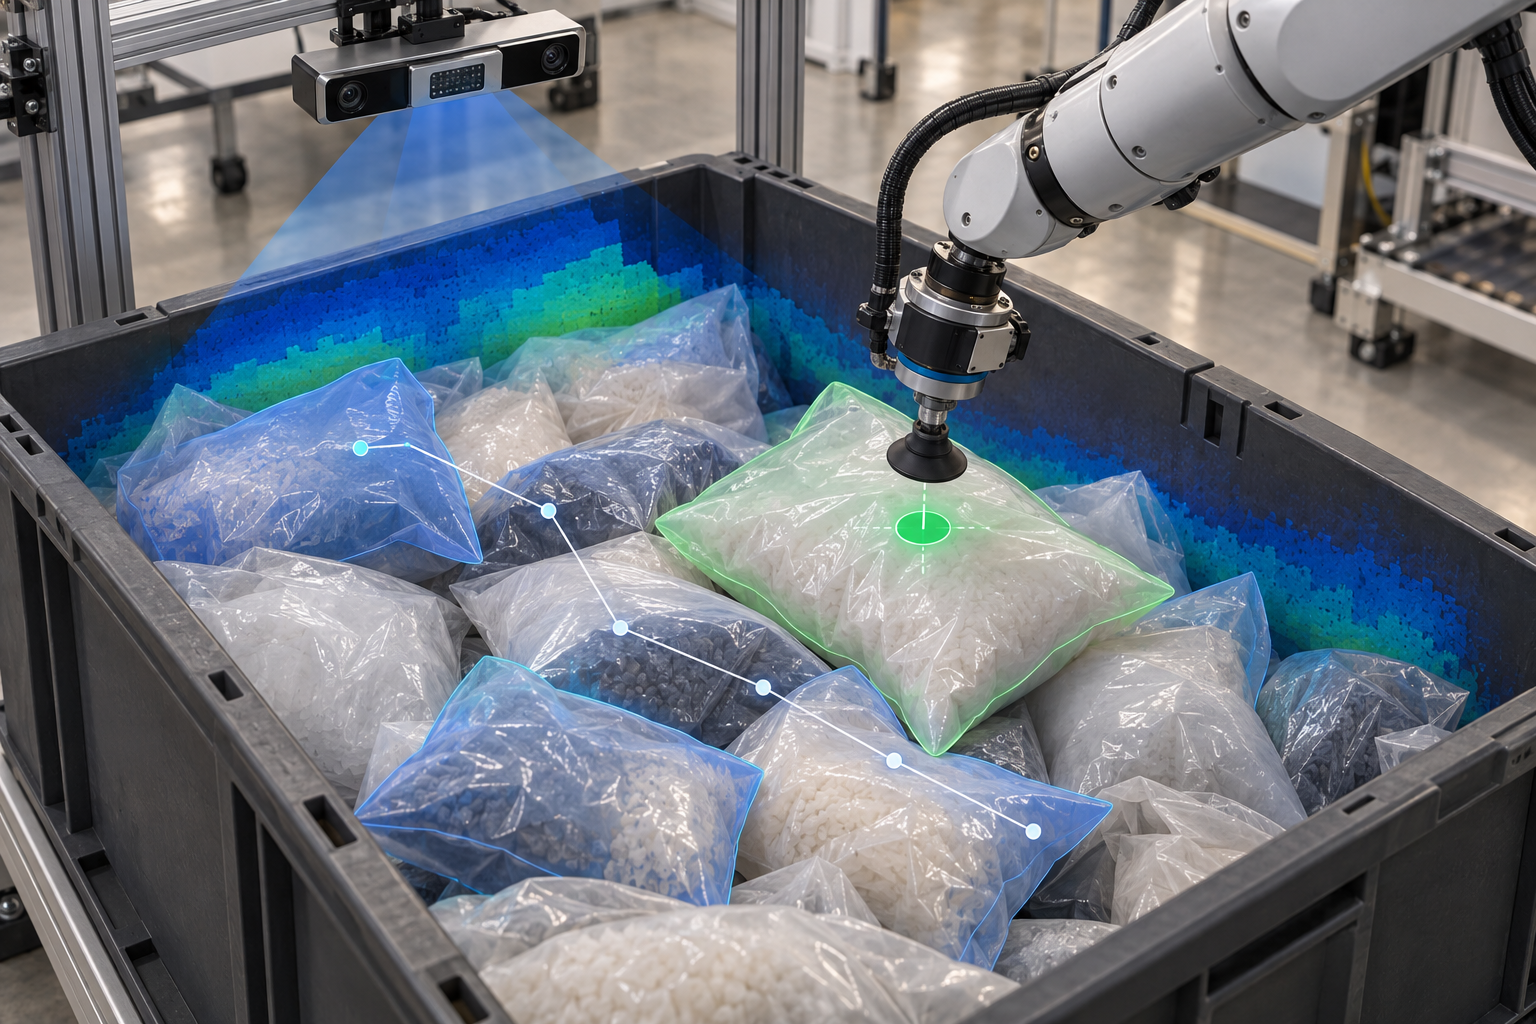
A perception-to-action pipeline for selecting and picking exposed flexible packages in cluttered, production-oriented scenes.
Robotics stack
Fluent across the stack required to turn robotics research into robust systems.
C++ · Python · C
ROS · ROS 2 · Pinocchio · EtherCAT
HQP · QP · IK · FK · MPC · VAJ
VLA · Imitation Learning · Vision
Linux · RTOS · SOEM · Real-time Runtime
Patents / IP
Published patent applications in robot motion planning and control. Unverified titles are intentionally omitted.
About
 JARVIS MEN · 2026
ENGINEER · BUILDER · SYSTEMS THINKER
Trained in Automation at the University of Science and Technology of China, I now develop motion-control systems for humanoid robotics. My work spans whole-body control, trajectory smoothing, singularity-aware IK, robot runtime safety and cross-team integration.
Previously, I built high-precision multi-axis and wafer-transfer robot controllers, achieving ±10 μm system-level commissioning accuracy, ±5 μm wafer-centering compensation and a 4× reduction in PDO communication jitter—from 200 μs to 50 μs.
Motion Control Development Engineer · Humanoid & Manipulation
High-Performance Computing Engineer
Motion Control Algorithm Engineer · Wafer Transfer Robotics
B.Eng. in Automation · Three merit scholarships
Available for meaningful robotics conversations